


10 Robot Vision System Buying Tips for Global Buyers?
Industrial automation is expanding, but purchasing decisions are becoming less forgiving. The International Federation of Robotics reported 541,302 industrial robots installed worldwide in 2023. More than 4.28 million robots were operating globally. Each robot needs reliable perception, not merely faster movement.
That is where a robot vision system becomes commercially important. A camera must identify parts under changing light, dust, reflections, and vibration. A packaging line may inspect hundreds of items each minute. A welding cell may need stable positioning within millimetres. Small errors can create rejected products, unplanned downtime, and difficult warranty discussions.
Industry reports offer useful direction, but they cannot replace line trials. The Association for Advancing Automation continues to track strong demand for robotics and machine vision across manufacturing. IFR’s World Robotics reports also show increasing adoption in automotive, electronics, logistics, and general industry. These figures confirm market momentum, not automatic return on investment.
Global buyers should examine sensor resolution, lens selection, processing speed, software compatibility, connectivity, service coverage, and total ownership cost. Regional support matters. So do spare parts, training, and integration experience. A low purchase price may hide expensive engineering work later.
No checklist is flawless. Some specifications look impressive on paper but fail beside a moving conveyor. A practical evaluation should test real products, real lighting, and real production speeds. This guide presents ten robot vision system buying tips for comparing suppliers with greater confidence, technical discipline, and commercial realism.
Define the Vision Task and Inspection Requirements
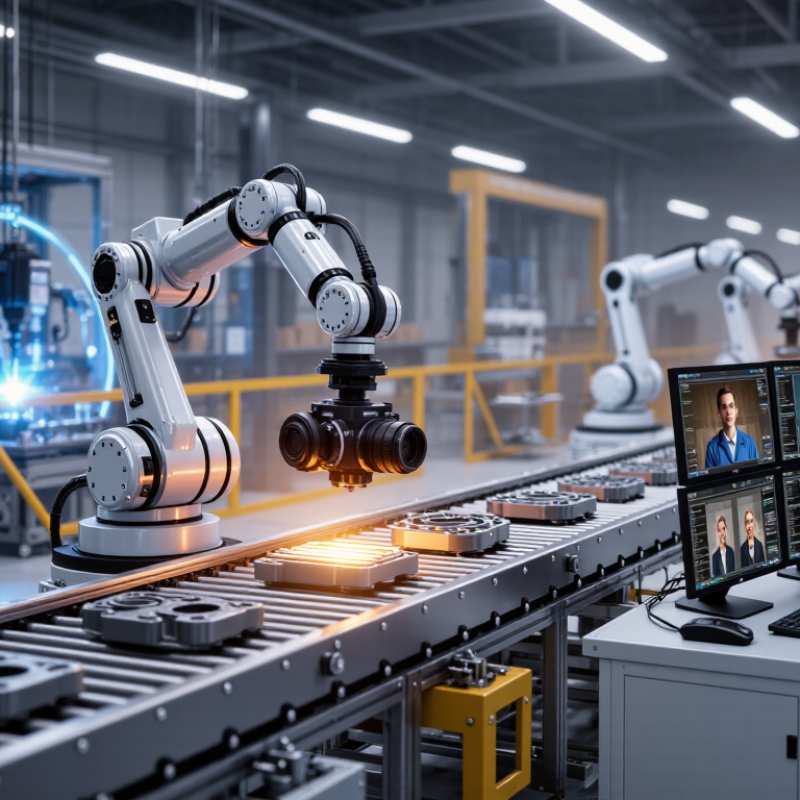
Before comparing robot vision systems, define the inspection task in measurable terms. What must the system detect, locate, measure, or classify? Record defect size, position tolerance, surface finish, object variation, and inspection speed. A vague goal such as “check quality” creates expensive confusion.
The International Federation of Robotics reported 541,302 industrial robots installed worldwide in 2023. More automated cells require clearer vision requirements, not simply more cameras. Specify the camera field of view, working distance, pixel resolution, lens distortion, lighting angle, and trigger timing. For example, a 0.2-millimeter defect needs enough pixels across that defect. A glossy metal part may need diffuse lighting, while a dark rubber seal may need controlled backlighting. Small details matter.
Set acceptance limits before testing hardware. Measure false rejects, missed defects, cycle time, and image-processing latency. Use representative samples, including clean parts, borderline defects, dust, scratches, and position changes. The International Data Corporation’s manufacturing research repeatedly identifies data quality as a major barrier to successful industrial AI deployment. That warning applies here. A perfect test sample is not a production environment. Teams sometimes underestimate vibration, lens contamination, seasonal light changes, or reflective packaging. The first design may still be wrong. Build a short pilot, preserve failed images, and review the inspection criteria with operators and quality engineers before approving the final system.
10 Robot Vision System Buying Tips for Global Buyers: Define the Vision Task and Inspection Requirements
| No. | Buying Tip | Vision Task | Inspection Requirement to Define | Typical Starting Specification | Key Acceptance Metric |
|---|---|---|---|---|---|
| 1 | Define the inspection objective | Presence, absence, or assembly verification | List every feature that must be confirmed, including component presence, orientation, count, and assembly position. | Binary pass/fail decision with a documented list of inspected features | False-accept rate and false-reject rate measured separately |
| 2 | Specify the defect type and size | Surface defect detection | Describe defect categories such as scratches, dents, cracks, stains, burrs, discoloration, or contamination, and provide the smallest critical defect. | Minimum detectable defect recorded in millimetres or pixels | Detection probability for the smallest critical defect |
| 3 | Measure the inspection area | Dimensional measurement and gauging | Define the field of view, measurement points, part tolerance, working distance, and whether the full part or selected regions require inspection. | Field of view selected so the critical feature occupies sufficient image area | Measurement repeatability and accuracy compared with the drawing tolerance |
| 4 | Calculate the required resolution | Small-feature inspection | Identify the smallest feature or defect and determine how many pixels must represent it for reliable classification or measurement. | At least several pixels across the smallest feature; higher sampling for precision measurement | Verified pixel-to-millimetre scale and repeatable results on production samples |
| 5 | Match the camera to object motion | Moving-part inspection | Document conveyor speed, robot movement, exposure time, image frequency, and the risk of motion blur. | Global or strobed illumination with exposure short enough to freeze the part | Blur-free images at the maximum validated production speed |
| 6 | Select suitable lighting | Contrast enhancement and reflective-surface inspection | Assess surface reflectivity, colour, transparency, texture, ambient light, and the direction from which defects are most visible. | Diffuse, coaxial, backlight, or directional lighting selected according to the surface and defect geometry | Stable contrast under normal operating and maintenance conditions |
| 7 | Define part-position variation | Robot guidance and object location | Specify allowable variation in position, rotation, height, occlusion, and presentation of randomly placed parts. | Required position and angle accuracy stated in millimetres and degrees | Successful pick or placement rate across the complete variation range |
| 8 | Set the cycle-time target | High-speed inspection and sorting | Record parts per minute, available inspection time, robot response time, image-processing time, and any reject mechanism delay. | System cycle time shorter than the line takt time with operational margin | Sustained throughput at peak line speed without missed triggers |
| 9 | Plan traceability and data handling | Code reading and inspection records | Define required code types, image retention period, inspection result fields, time stamps, serial numbers, and export format. | Unique product identifier linked to the pass/fail result and stored inspection image when required | Read rate, record completeness, retrieval time, and data-integrity checks |
| 10 | Validate with representative samples | Production-ready system acceptance | Test good parts, known defective parts, borderline samples, different batches, environmental changes, and the full operating range. | Acceptance test based on a statistically meaningful sample set and agreed pass/fail rules | Detection performance, uptime, repeatability, and operator usability in production conditions |
Related Posts
-
What is Robot News and How it is Changing the Future of Journalism
-
Unlocking the Future of Automation with Advanced Robot Vision Systems
-
Exploring the Future of Robotic Vision: Innovations That Transform Industries
-
7 Best 3D Vision Systems for Robots: Enhance Automation & Efficiency
-
Unlocking the Future of Automation with Revolutionary Robot Software
-
Top Camera Robots for Photography and Filmmaking Innovations?